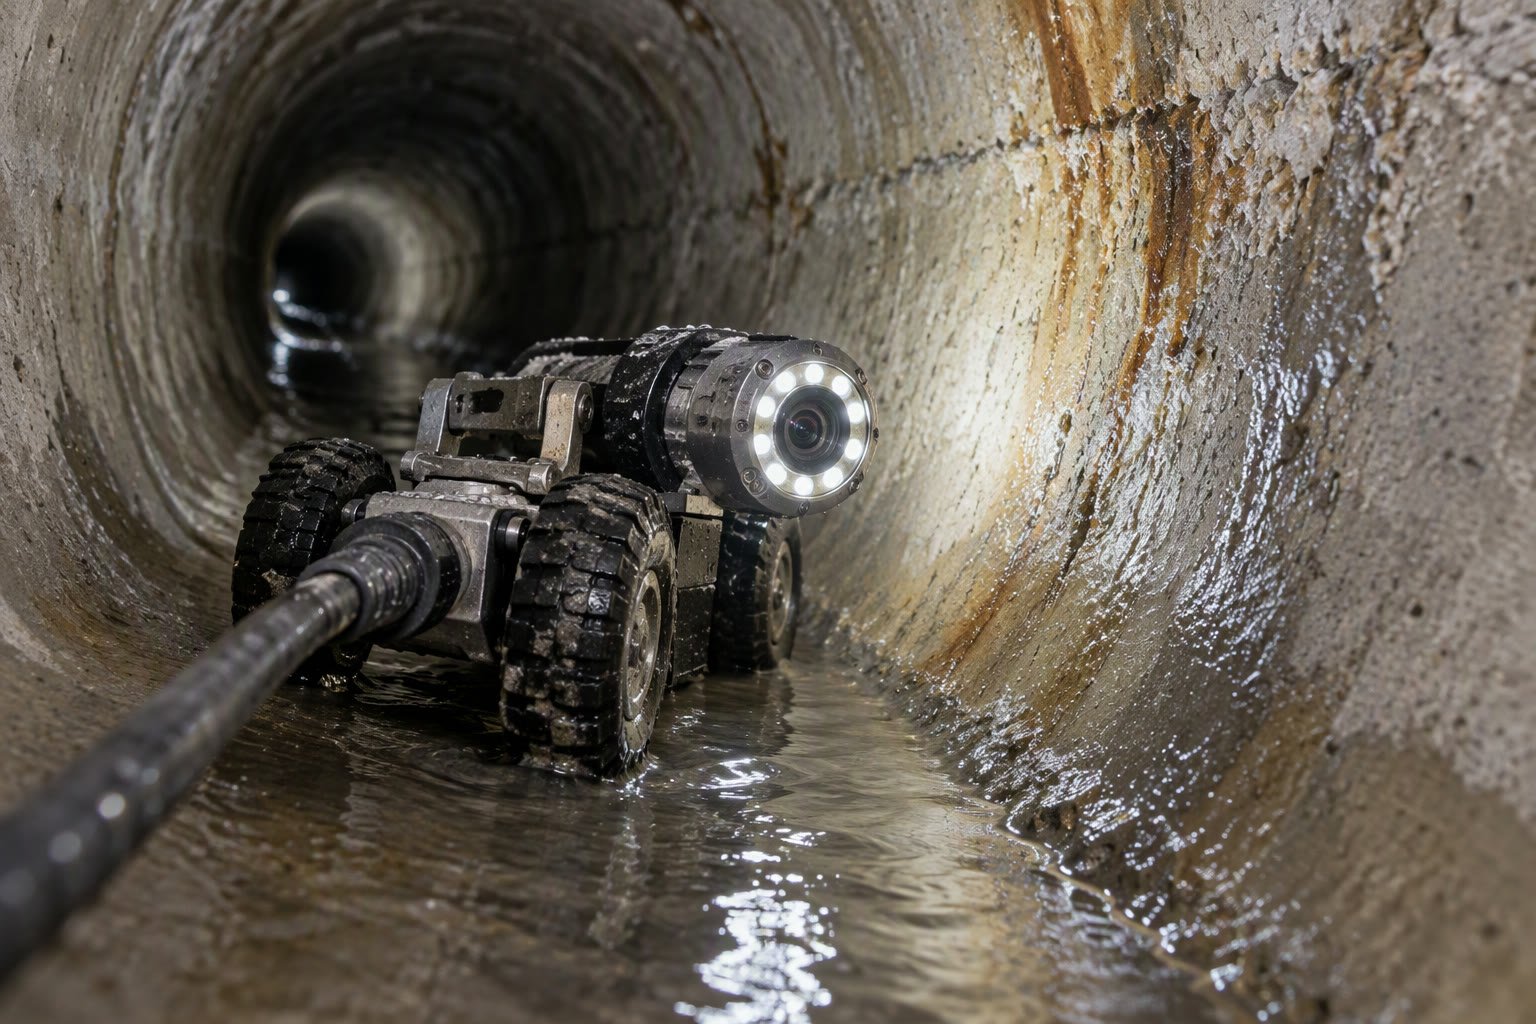
A pipe inspection robot is a camera on wheels that goes where a person should not. In India that is usually a sewer line under a city street, a storm drain, or a duct in a plant. The machines range from a ₹1.5 lakh push-rod camera to a ₹40 lakh mainline crawler, and the difference between them is mostly pipe diameter, cable length and how much the software does.
Why inspection robots exist
Sewer and drain work is one of the most dangerous jobs in India. Confined spaces can hold hydrogen sulphide, methane and low oxygen, and entry without gas testing and rescue equipment kills workers every year. The Prohibition of Employment as Manual Scavengers and their Rehabilitation Act, 2013 prohibits hazardous manual cleaning of sewers and septic tanks, which pushed municipalities and contractors toward machine inspection.
The engineering reason is just as strong. A camera record with a distance reading lets an engineer assign a defect code, grade its severity and compare the same pipe next year. A crew looking into a manhole with a torch produces an opinion, not a record.
The four machine types
| Type | Pipe size | How it moves | Typical use |
|---|---|---|---|
| Push-rod camera | 50–200 mm | Flexible rod pushed by hand | House connections, short laterals, inspection before lining |
| Wheeled CCTV crawler | 150–1,500 mm | Self-propelled, tethered | Municipal sewers, storm drains, condition surveys |
| Mainline crawler | 200–2,000 mm | Heavy crawler, long cable, pan-tilt-zoom head | Trunk sewers, large drains, interstate surveys |
| Duct / wall climber | 100–600 mm rectangular | Wheels or tracks pressed against walls | HVAC ducts, industrial ventilation |
Pipeline “pigs” are a separate family used in oil, gas and water mains. They are pushed by the product flow and record geometry, corrosion or leaks over kilometres. They are not remotely controlled, and they are a different purchase from a sewer crawler.
What is inside a crawler
- Chassis and drive: four or six wheels, often with adjustable track width and height so one machine covers several pipe sizes. Tyres are changed for different surfaces.
- Camera head: a colour camera on a pan-and-tilt mechanism, surrounded by an LED ring. Resolution ranges from 480 TVL analogue to 1080p or 4K digital.
- Lighting: the LED ring must be bright enough for a 1,000 mm pipe and dimmable, or the near wall blows out and the far wall stays dark.
- Cable and reel: the tether carries video, power and control. The reel counts cable payout so the operator knows the camera’s distance from the manhole.
- Control unit: a rugged laptop or console that records video, overlays distance and time, and lets the operator steer and tilt.
- Software: observation coding, defect grading and report generation. This is where cheap systems fall apart.
The camera head and the cable are the parts that fail. Water ingress destroys a camera that was rated IP68 on paper but assembled with a dry O-ring, and a cable crushed at a manhole edge takes the whole survey out of service.
Coding and grading: the part clients pay for
In the UK and much of the Commonwealth, sewer defects are coded with the WRc Manual of Sewer Condition Classification. In North America the equivalent is NASSCO’s Pipeline Assessment Certification Program (PACP). Both systems describe the same things: cracks, fractures, roots, infiltration, debris, settlement, deformation, displaced joints and surface damage.
Each observation is recorded with a distance, a clock position around the pipe wall and a severity grade, usually 1 to 5. A structural defect graded 4 or 5 in a trunk sewer can trigger rehabilitation; the same defect in a lateral may only be monitored. The value of the survey is that two engineers looking at the same footage reach the same conclusion.
| Defect group | Examples | What it suggests |
|---|---|---|
| Structural | Crack, fracture, broken pipe, collapse | Loss of load capacity; repair or lining may be needed |
| Operational | Roots, debris, grease, scale | Blockage risk; cleaning first, then re-inspect |
| Joint | Displaced joint, open joint, offset | Infiltration and root entry points |
| Geometry | Sag, deformation, pipe ovality | Poor bedding, overload or settlement |
| Connection | Intruding lateral, defective connection | Local repair; often the source of infiltration |
What the equipment costs in India
These are indicative market ranges for planning. Imported mainline systems, software licences and calibration add substantially, and municipal tenders often specify a particular coding standard, which decides the software before the hardware.
| System | Indicative price | Notes |
|---|---|---|
| Push-rod camera, 30–50 m cable | ₹1.5–4 lakh | House laterals and small drains; no self-propulsion |
| Wheeled crawler, 150–600 mm | ₹8–18 lakh | Camera, reel, control unit; coding software may be extra |
| Mainline crawler, 300–1,500 mm | ₹20–45 lakh | Long cable, pan-tilt-zoom head, stronger drive |
| Survey-grade software | ₹1–5 lakh | PACP or WRc coding, report templates, licence terms vary |
| Rental, crawler with operator | ₹8,000–25,000 per day | Common for one-off surveys and municipal pilots |
| Cost of getting it wrong | What happens |
|---|---|
| Camera floods | ₹40,000–₹2 lakh to repair or replace the head |
| Wrong pipe range | Machine cannot enter the smallest laterals in the network |
| No distance counter | Footage is unusable for tenders and repeat surveys |
| Software without the required standard | Reports rejected by the client after the survey is done |
Buying checklist for pipe inspection robots
- Pipe range: list the smallest and largest diameters in the network, then add margin. A machine that fits 200–800 mm is useless if half the laterals are 150 mm.
- Cable length: manhole spacing decides it. Add 20% for routing around the reel and up the ladder.
- IP rating and pressure: IP68 is a starting point. Ask for the depth rating and the test method, not the marketing line.
- Lighting: dimmable LED ring with enough output for the largest pipe. Ask for sample footage in a dirty, water-filled pipe, not a clean demo pipe.
- Distance accuracy: cable counter should be calibrated and resettable, and the overlay should be burned into the recording.
- Power: battery runtime for a full shift, plus a spare. Some units run from mains and need a generator on site.
- Software: does it export the coding standard your clients use, with photos and a report? Can you edit codes after the survey?
- Service: an Indian service partner and spare camera heads matter more than a lower purchase price.
- Safety kit: gas detector, blower, harness, tripod and winch are part of the job, not accessories.
Build a small crawler for a 100–150 mm pipe
A maker-grade crawler is a reasonable learning project and can inspect a 100–150 mm pipe for a few thousand rupees. It will not replace a survey crawler: the camera is not survey-grade, the tether is short, and there is no coding software. It is a way to see inside a blocked line before calling a contractor.
| Part | Suggested item | Indicative price |
|---|---|---|
| Controller and camera | ESP32-CAM | ₹500–₹900 |
| Drive | Two N20 gear motors with wheels | ₹600–₹1,200 |
| Motor driver | TB6612FNG or DRV8833 | ₹150–₹400 |
| Lighting | 3 W white LED plus driver, or a bright LED ring | ₹100–₹400 |
| Power | 2S 18650 pack with protection | ₹500–₹1,000 |
| Chassis | 3D-printed body with silicone tread | ₹300–₹800 |
| Tether | USB cable or 4-core cable, 5–10 m | ₹200–₹600 |
The firmware is a small web server that streams the camera and accepts drive commands. Keep the speed low: a crawler that flips inside a pipe is a recovery problem, and the tether is your only handle.
#include "esp_camera.h"
#include "WiFi.h"
#include "WebServer.h"

#define AIN1 12
#define AIN2 13
#define PWMA 14
#define BIN1 15
#define BIN2 2
#define PWMB 4

WebServer server(80);

void drive(int left, int right) {
  digitalWrite(AIN1, left >= 0);
  digitalWrite(AIN2, left < 0);
  digitalWrite(BIN1, right >= 0);
  digitalWrite(BIN2, right < 0);
  analogWrite(PWMA, abs(left));
  analogWrite(PWMB, abs(right));
}

void setup() {
  pinMode(AIN1, OUTPUT); pinMode(AIN2, OUTPUT); pinMode(PWMA, OUTPUT);
  pinMode(BIN1, OUTPUT); pinMode(BIN2, OUTPUT); pinMode(PWMB, OUTPUT);
  Serial.begin(115200);
  // camera_config_t omitted for brevity; use the ESP32-CAM example config
  WiFi.begin("ssid", "password");
  server.on("/", []() { server.send(200, "text/plain", "crawler ready"); });
  server.on("/drive", []() {
    int l = server.arg("l").toInt();
    int r = server.arg("r").toInt();
    drive(constrain(l, -255, 255), constrain(r, -255, 255));
    server.send(200, "text/plain", "ok");
  });
  server.begin();
}

void loop() { server.handleClient(); }
Two things make the difference between usable footage and a blurry mess: light close to the lens, and a cable that does not drag the chassis sideways. Fix the camera focus at the distance you actually inspect, usually 150–400 mm from the lens.
Common questions
How much does a sewer inspection robot cost in India?
A push-rod camera starts around ₹1.5 lakh. A wheeled crawler for 150–600 mm pipes is roughly ₹8–18 lakh, and a mainline crawler ₹20–45 lakh. Survey software with PACP or WRc coding is often priced separately.
Can a robot replace manual sewer cleaning?
It replaces inspection and can carry cleaning tools, but it does not remove the need for trained crews, gas testing and confined-space procedure. It removes the need for a person to enter the pipe to look.
What is PACP?
The Pipeline Assessment Certification Program from NASSCO, a standard way of coding and grading sewer defects so reports are consistent between operators and contractors.
Which camera resolution is enough?
1080p is the practical minimum for survey work in pipes above 200 mm. Resolution matters less than lighting and a clean lens.
Can I build a pipe inspection robot for a school project?
Yes. An ESP32-CAM, two geared motors, a motor driver and a 3D-printed body cost well under ₹5,000 and demonstrate the principle. It is not a substitute for a certified survey system.
Related: ESP32-CAM guide, ESP32-CAM robot car, TB6612FNG motor driver, robotics in manufacturing.
For mobile platforms, AGV vs AMR compares fixed-path and free-navigation robots.
Sources and further reading
- NASSCO PACP — pipeline assessment and certification programme.
- WRc — sewer condition classification manuals.
- OSHA confined spaces — the hazards that make robotic inspection preferable to entry.
- Pipeline inspection — overview of pigs, crawlers and in-line tools.
Last reviewed: October 2026. Prices are indicative Indian market ranges for planning, not quotations. Defect classifications vary by standard and client specification. Not bench-tested by this site.

