Buying guides
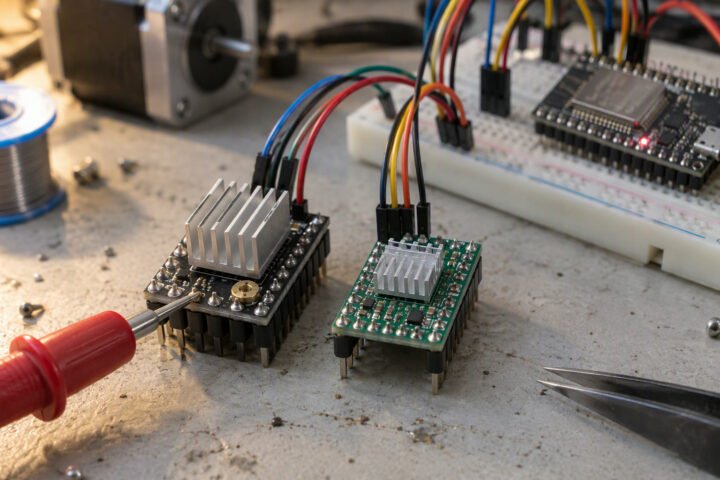
Stepper Driver Checklist: Current, Voltage and Microstepping
Checklist for choosing a stepper driver: motor current, supply headroom, microstepping, noise, heat and wiring protection.
Executive Author Profile · 323 guides
Jignesh S Panchal is the Founder of Jaadu Digital and Musafir Infotech, and the Publisher of Robotics Engineering (roboticsengineering.in). With 9+ years of hands-on experience in industrial marketing, B2B engineering systems, and manufacturing & robotics automation workflows in India, he oversees editorial direction, rupee BOM verification, and standards-reviewed build guides.
Buying guides
Checklist for choosing a stepper driver: motor current, supply headroom, microstepping, noise, heat and wiring protection.
Tutorials
Denavit-Hartenberg (DH) parameters describe each link of a robot arm with four numbers, which you place in a table and turn into…
Buying guides
Engineering guide comparing AMRs and AGVs for smart factories and warehouses: SLAM navigation, ISO 3691-4 safety zones, VDA 5050 orchestration, floor tolerances,…
Buying guides
Engineering comparison of collaborative robots vs 6-axis industrial arms covering ISO/TS 15066 risk assessment, wrist inertia limits, cycle speed, and India CAPEX/ROI.
Tutorials
Engineering guide to 2D/2.5D/3D vision physics, eye-in-hand vs eye-to-hand calibration, specular glare mitigation, and edge AI defect detection for robotic manufacturing cells.
Tutorials
Complete engineering architecture of Physical AI in manufacturing: 5-layer control stack, VLA vs deterministic 1 kHz loops, Isaac Sim domain randomization, and…
Tutorials
How two channels 90 degrees apart give direction, with a state table, x4 counting and Arduino decoding code.
Tutorials
How internal resistance causes voltage sag, how to measure it with two loads, and a worked 3S2P robot pack example.
Tutorials
Why a stepper shakes or loses steps in certain speed bands, and how current, microstepping, load and damping change it.
Buying guides
What to check when buying a bench power supply for robot testing: range, current limit, display, noise and protection.