Tutorials
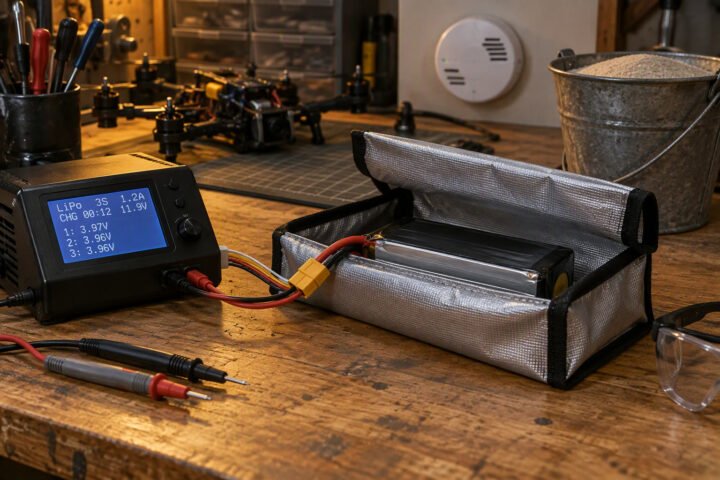
LiPo battery safety for robots: charging, storage and fires
How to charge, store and wire LiPo packs on a robot: cell voltages, cut-off traps, fusing, BMS choices and what to do…
Executive Author Profile · 323 guides
Jignesh S Panchal is the Founder of Jaadu Digital and Musafir Infotech, and the Publisher of Robotics Engineering (roboticsengineering.in). With 9+ years of hands-on experience in industrial marketing, B2B engineering systems, and manufacturing & robotics automation workflows in India, he oversees editorial direction, rupee BOM verification, and standards-reviewed build guides.
Tutorials
How to charge, store and wire LiPo packs on a robot: cell voltages, cut-off traps, fusing, BMS choices and what to do…
Careers
The mechanical questions robotics interviews ask: fits, materials, bearings, mechanisms, motor sizing and design for manufacture, with answer notes.
Tutorials
Size pneumatic cylinders properly: bore selection, force per bar, air consumption, compressor sizing, speed control and gripper force checks.
Tutorials
Ackermann steering for robot builds: wheel angle geometry, linkage choices, servo sizing, path curvature control and odometry integration.
Tutorials
Six-axis force torque sensing explained: technologies, the specs that matter, gravity compensation, admittance control and a cheap load cell start.
Tutorials
Fuse accelerometer and gyroscope on an Arduino: the alpha equation, loop timing, gyro bias calibration and the failure cases that break the…
Careers
The embedded interview questions Indian robotics employers ask: C fundamentals, interrupts, protocols, RTOS, power and debugging, with answer notes.
Tutorials
Design a small robot controller board in KiCad: power blocks, trace width for motor current, grounding, protection, connectors and safe bring-up.
Tutorials
Size a vacuum gripper properly: holding force, safety factors, cup types, ejector versus pump, flow on porous parts, sensing and failure modes.
Tutorials
Detect ArUco markers in OpenCV and turn them into a metric robot pose: dictionaries, solvePnP, pose ambiguity, accuracy limits and docking tips.