Tutorials
ROS 2 sensor fusion: wheel odometry and IMU
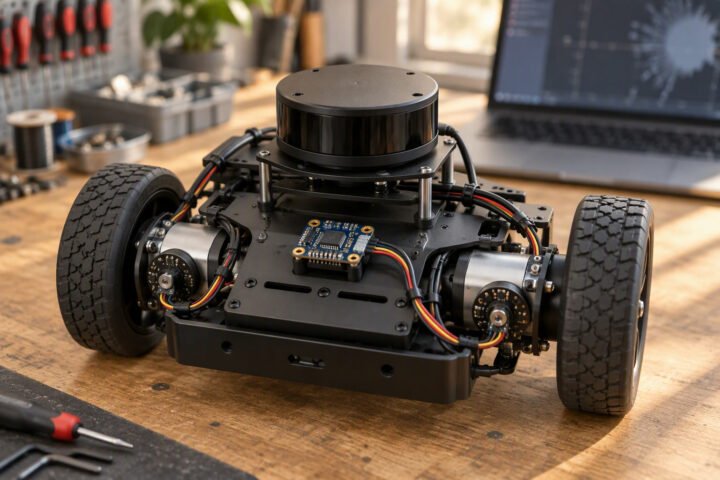
Fuse wheel odometry and IMU in ROS 2: robot_localization config, covariances, the two-filter layout and the mistakes that make fusion worse.
Executive Author Profile · 323 guides
Jignesh S Panchal is the Founder of Jaadu Digital and Musafir Infotech, and the Publisher of Robotics Engineering (roboticsengineering.in). With 9+ years of hands-on experience in industrial marketing, B2B engineering systems, and manufacturing & robotics automation workflows in India, he oversees editorial direction, rupee BOM verification, and standards-reviewed build guides.
Tutorials
Fuse wheel odometry and IMU in ROS 2: robot_localization config, covariances, the two-filter layout and the mistakes that make fusion worse.
Tutorials
Run YOLO on a robot: frame-rate budget, model size, dataset, export formats, turning boxes into 3D positions and the failures seen in…
Tutorials
Compare harmonic and cycloidal reducers on backlash, shock load, efficiency and cost, and see which joint on a robot should use each.
Buying guides
Rated payload is not usable payload. Calculate tool mass, centre of gravity, moment and inertia, and know what to ask a vendor…
Tutorials
What a BMS protects, protection board vs smart BMS, how to size the current rating, and the balance-lead wiring mistakes that destroy…
Tutorials
Put an ESP32-CAM on a robot: wiring and power, the CameraWebServer path, realistic latency, and when a Raspberry Pi or Jetson becomes…
Tutorials
Compare NEMA 17 and NEMA 23 steppers on torque, current, drivers, voltage and Indian prices, and see how to size an axis…
Tutorials
URDF describes a robot for ROS; SDF describes a world for Gazebo. Learn the differences, how conversion works and the workflow that…
Tutorials
Record the right topics, compress sensibly, replay with simulated time and avoid the QoS and storage mistakes that make a rosbag useless.
Tutorials
Learn teach pendant programming across FANUC, KUKA, ABB and Yaskawa: operating modes, coordinate frames, motion instructions and safe practice.