Tutorials
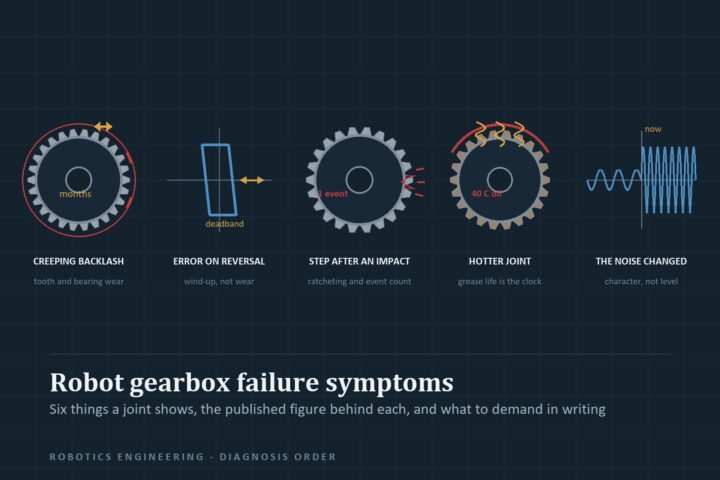
Robot gearbox failure symptoms: work through them in this order
Robot gearbox failure symptoms read in order: creeping backlash, reversal-only error, post-collision ratcheting, heat and grease life, encoder false positives.
Learn
Plain-English tutorials that build on each other: a pin, a sensor, a control loop, a node. Written for people who have to make the robot move.
Everything here is written to be used on a bench, not admired on a slide. Each guide answers one question a builder actually hits: why the servo browns out the board, why the sensor reading jumps, which board to buy with ₹3,000, what an examiner expects in the report. Prices are planning ranges in rupees, and every build sheet says what it has not tested. These robotics tutorials are written to be used on a bench, and each one answers a single question builders hit.
These guides cover the industrial side: what a robot cell costs in India, what a safety audit has to test, and what a maintenance contract or insurance policy actually covers.
Every article is reviewed against manufacturer datasheets and current Indian listings, then dated. Nothing on this site claims a physical build test unless the article says so and shows the evidence. If a guide conflicts with a datasheet or a safety standard, the datasheet wins — see the editorial standard for the full process.
If you have never powered a motor, read the power guide and the battery guide before buying a driver. If you have a project deadline, read the final-year project list and the report format together; the build is only half the marks. If you are choosing a branch specialisation, start with the careers guide and then build one project from the library so the interview has something concrete to discuss.
Building a machine for a factory rather than a bench? The industrial robotics guides apply the same engineering discipline at plant scale: specifying the robot, commissioning the cell and proving it is safe.
No. The site has a guide to learning the control logic and code without buying parts first, so you can start with a simulator or an emulator and buy components once you know what the build needs.
Most beginner projects here use an Arduino Uno or an Arduino Nano, because the parts are cheap and widely documented in India. Move to an ESP32 when you need WiFi or faster processing.
Each project page lists its parts with rupee prices, so you can cost a build before ordering anything.
The guides set out a parts list, the wiring and a test that proves the build works, which is the evidence most submissions are marked on. Check your department requirements before you rely on them.
Tutorials
Robot gearbox failure symptoms read in order: creeping backlash, reversal-only error, post-collision ratcheting, heat and grease life, encoder false positives.
Tutorials
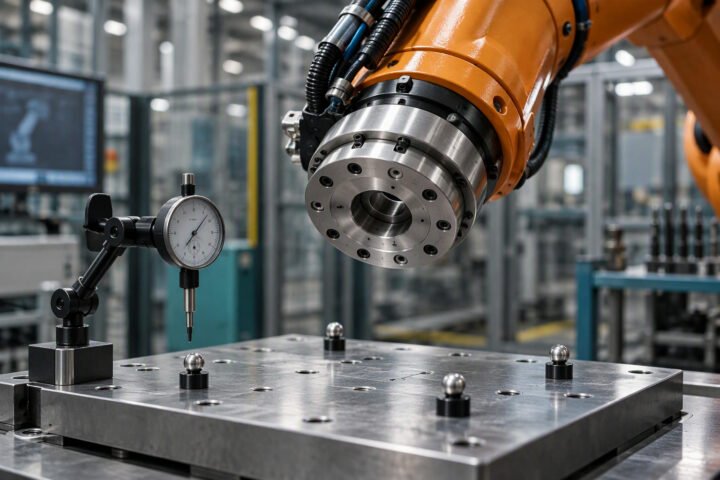
Measure gearbox backlash with a dial indicator, backdrive or servo trace, then convert the reading to arcminutes and millimetres at the tool…
Careers
Which parts of a B.Tech mechanical degree carry into robotics, which Indian job advertisement lists your branch, and how to choose between…
Tutorials
Harmonic drive vs planetary gearbox on lost motion, stiffness, heat and L10 life, with the catalogue numbers that decide which one fits…
Tutorials
A robot gearhead is picked in a fixed order: lost motion at the tool tip, then rated and peak torque with the…
Tutorials
Set the required performance level (PLr) for a robot cell safety function under ISO 13849-1: risk graph, MTTFd, diagnostic coverage, datasheet checks.
Buying guides
Robot cell insurance in India: fire and machinery breakdown cover, electronics cover, how to set the sum insured, what lenders require and…
Buying guides
How Indian MSMEs fund an industrial robot: term loans, CGTMSE collateral-free cover, SIDBI machinery finance, and the documents lenders ask for.
Tutorials
Site checks before an industrial robot arrives in India: slab thickness and anchors, 3-phase supply, grounded neutral, earthing and voltage sag.
Buying guides
Most inspection projects fail for a reason that has nothing to do with the camera. The camera finds the defect; the line…