Tutorials
ROS 2 QoS tutorial: reliability, durability and depth
Why a ROS 2 topic stays silent: how reliability, durability, history and depth interact, which profiles to use, and how to diagnose…
Learn
Plain-English tutorials that build on each other: a pin, a sensor, a control loop, a node. Written for people who have to make the robot move.
Everything here is written to be used on a bench, not admired on a slide. Each guide answers one question a builder actually hits: why the servo browns out the board, why the sensor reading jumps, which board to buy with ₹3,000, what an examiner expects in the report. Prices are planning ranges in rupees, and every build sheet says what it has not tested. These robotics tutorials are written to be used on a bench, and each one answers a single question builders hit.
These guides cover the industrial side: what a robot cell costs in India, what a safety audit has to test, and what a maintenance contract or insurance policy actually covers.
Every article is reviewed against manufacturer datasheets and current Indian listings, then dated. Nothing on this site claims a physical build test unless the article says so and shows the evidence. If a guide conflicts with a datasheet or a safety standard, the datasheet wins — see the editorial standard for the full process.
If you have never powered a motor, read the power guide and the battery guide before buying a driver. If you have a project deadline, read the final-year project list and the report format together; the build is only half the marks. If you are choosing a branch specialisation, start with the careers guide and then build one project from the library so the interview has something concrete to discuss.
Building a machine for a factory rather than a bench? The industrial robotics guides apply the same engineering discipline at plant scale: specifying the robot, commissioning the cell and proving it is safe.
No. The site has a guide to learning the control logic and code without buying parts first, so you can start with a simulator or an emulator and buy components once you know what the build needs.
Most beginner projects here use an Arduino Uno or an Arduino Nano, because the parts are cheap and widely documented in India. Move to an ESP32 when you need WiFi or faster processing.
Each project page lists its parts with rupee prices, so you can cost a build before ordering anything.
The guides set out a parts list, the wiring and a test that proves the build works, which is the evidence most submissions are marked on. Check your department requirements before you rely on them.
Tutorials
Why a ROS 2 topic stays silent: how reliability, durability, history and depth interact, which profiles to use, and how to diagnose…
Tutorials
Build an Android controller for an ESP32 robot: transport choices, joystick mixing, the command watchdog and the Wi-Fi problems that break demos.
Tutorials
Tune ROS 2 Nav2 costmaps: footprint, inflation radius, cost scaling, observation sources and a symptom-to-parameter table that saves test runs.
Tutorials
Learn ladder logic through worked examples: start-stop seal-in, latches, timers, counters, a robot handshake and the mistakes behind intermittent faults.
Tutorials
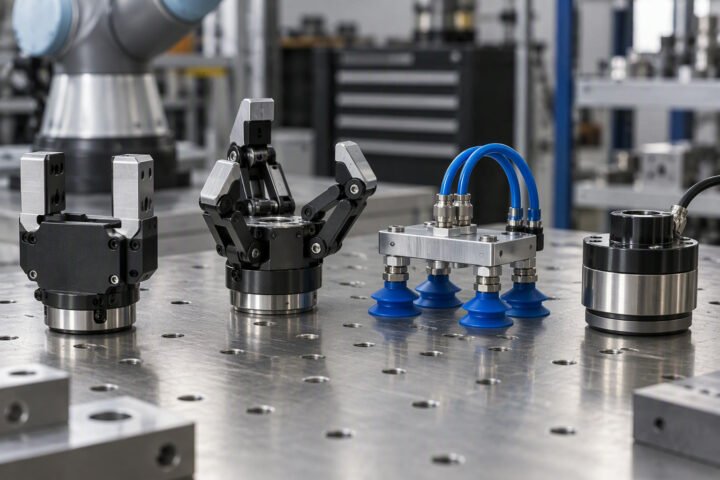
Mechanical grippers, vacuum, magnetic, soft and process tools compared: how each grips, where each fails and how to choose for your part.
Tutorials
Fuse wheel odometry and IMU in ROS 2: robot_localization config, covariances, the two-filter layout and the mistakes that make fusion worse.
Tutorials
Run YOLO on a robot: frame-rate budget, model size, dataset, export formats, turning boxes into 3D positions and the failures seen in…
Tutorials
Compare harmonic and cycloidal reducers on backlash, shock load, efficiency and cost, and see which joint on a robot should use each.
Buying guides
Rated payload is not usable payload. Calculate tool mass, centre of gravity, moment and inertia, and know what to ask a vendor…
Tutorials
What a BMS protects, protection board vs smart BMS, how to size the current rating, and the balance-lead wiring mistakes that destroy…