Tutorials
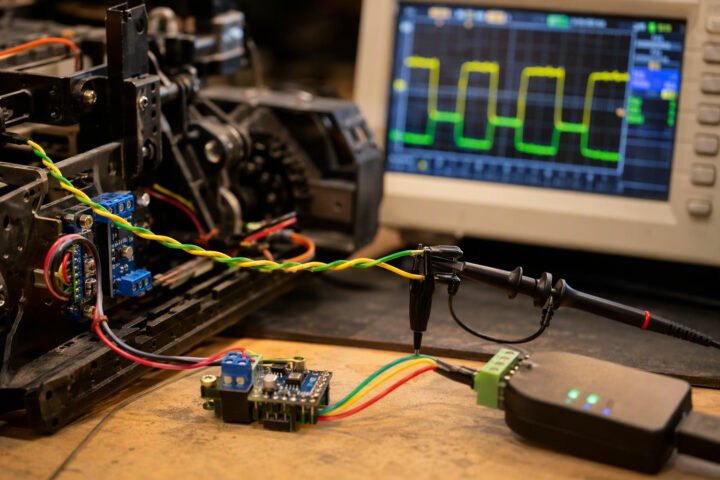
CAN bus for robots: wiring, messages and debugging
How CAN bus works on a robot: termination rules, frame format, a sane message map, SocketCAN commands and Python, plus the faults…
Learn
Plain-English tutorials that build on each other: a pin, a sensor, a control loop, a node. Written for people who have to make the robot move.
Everything here is written to be used on a bench, not admired on a slide. Each guide answers one question a builder actually hits: why the servo browns out the board, why the sensor reading jumps, which board to buy with ₹3,000, what an examiner expects in the report. Prices are planning ranges in rupees, and every build sheet says what it has not tested. These robotics tutorials are written to be used on a bench, and each one answers a single question builders hit.
These guides cover the industrial side: what a robot cell costs in India, what a safety audit has to test, and what a maintenance contract or insurance policy actually covers.
Every article is reviewed against manufacturer datasheets and current Indian listings, then dated. Nothing on this site claims a physical build test unless the article says so and shows the evidence. If a guide conflicts with a datasheet or a safety standard, the datasheet wins — see the editorial standard for the full process.
If you have never powered a motor, read the power guide and the battery guide before buying a driver. If you have a project deadline, read the final-year project list and the report format together; the build is only half the marks. If you are choosing a branch specialisation, start with the careers guide and then build one project from the library so the interview has something concrete to discuss.
Building a machine for a factory rather than a bench? The industrial robotics guides apply the same engineering discipline at plant scale: specifying the robot, commissioning the cell and proving it is safe.
No. The site has a guide to learning the control logic and code without buying parts first, so you can start with a simulator or an emulator and buy components once you know what the build needs.
Most beginner projects here use an Arduino Uno or an Arduino Nano, because the parts are cheap and widely documented in India. Move to an ESP32 when you need WiFi or faster processing.
Each project page lists its parts with rupee prices, so you can cost a build before ordering anything.
The guides set out a parts list, the wiring and a test that proves the build works, which is the evidence most submissions are marked on. Check your department requirements before you rely on them.
Tutorials
How CAN bus works on a robot: termination rules, frame format, a sane message map, SocketCAN commands and Python, plus the faults…
Buying guides
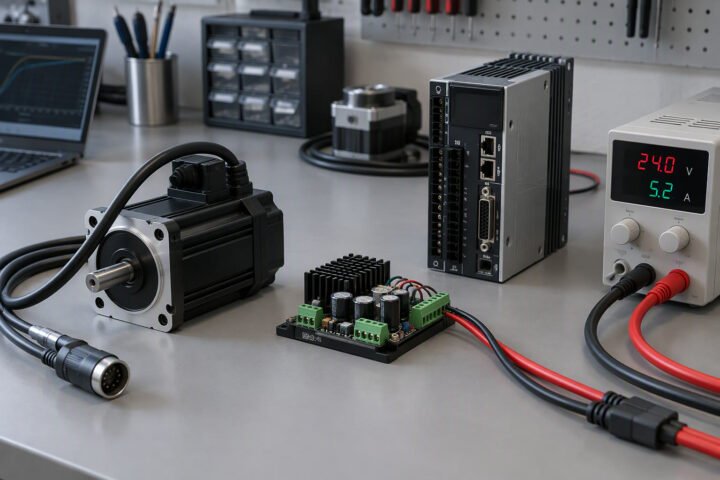
How to choose between hobby controllers, integrated servo motors and industrial drives: current ratings, feedback, regeneration, interfaces and cost bands in India.
Tutorials
Why and when to move from Arduino to STM32, board selection, CubeMX setup, 20 kHz PWM, hardware encoder counting, current sensing and…
Tutorials
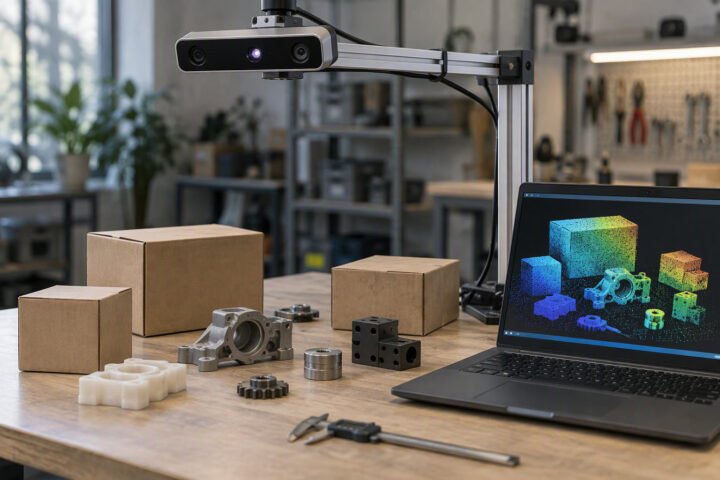
Stereo, structured light and time-of-flight depth cameras compared, with accuracy limits, point cloud filtering, ROS 2 setup and buying advice for India.
Tutorials
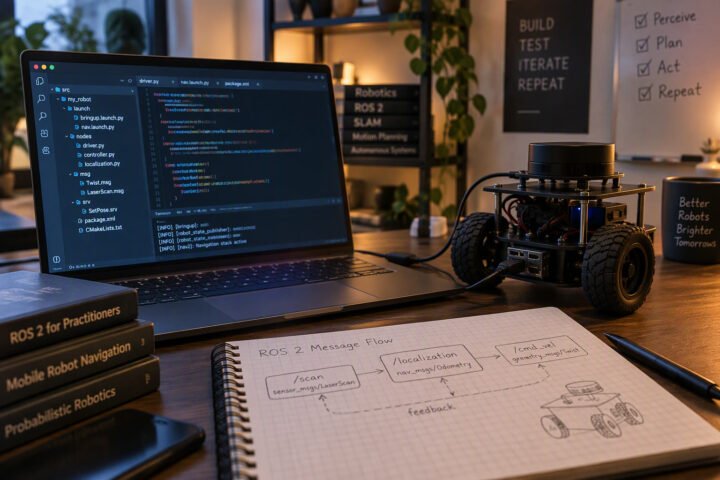
How to define msg, srv and action files, build them with rosidl, publish from Python and avoid the interface versioning traps that…
Tutorials
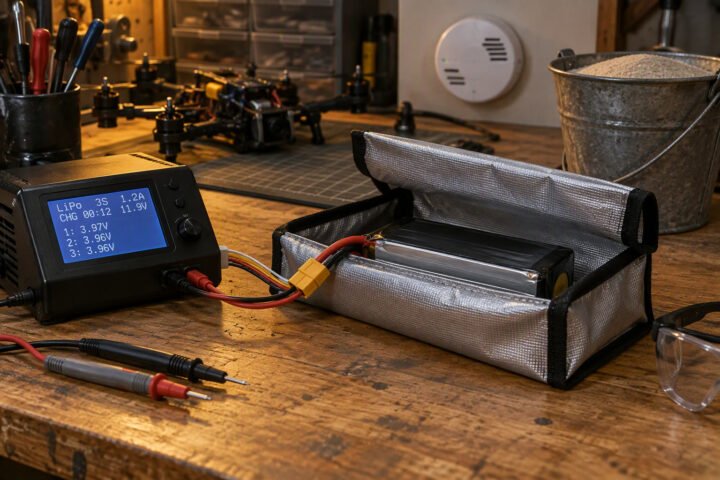
How to charge, store and wire LiPo packs on a robot: cell voltages, cut-off traps, fusing, BMS choices and what to do…
Careers
The mechanical questions robotics interviews ask: fits, materials, bearings, mechanisms, motor sizing and design for manufacture, with answer notes.
Tutorials
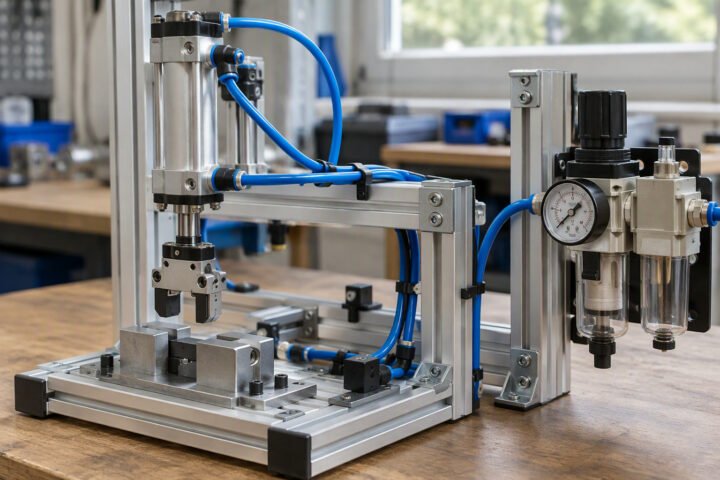
Size pneumatic cylinders properly: bore selection, force per bar, air consumption, compressor sizing, speed control and gripper force checks.
Tutorials
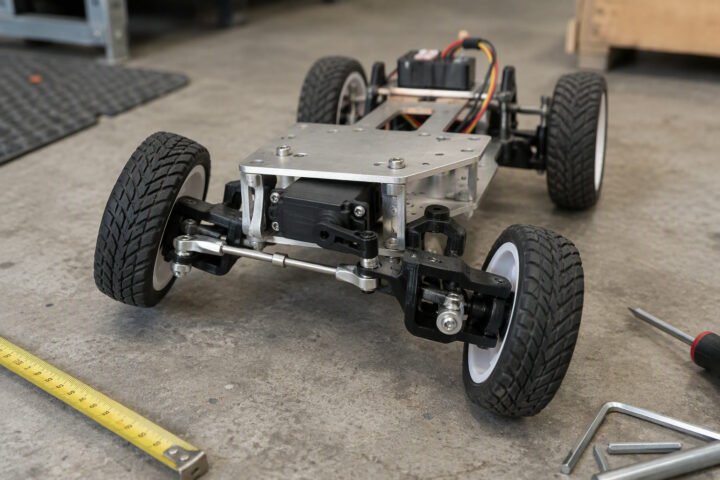
Ackermann steering for robot builds: wheel angle geometry, linkage choices, servo sizing, path curvature control and odometry integration.
Tutorials
Six-axis force torque sensing explained: technologies, the specs that matter, gravity compensation, admittance control and a cheap load cell start.